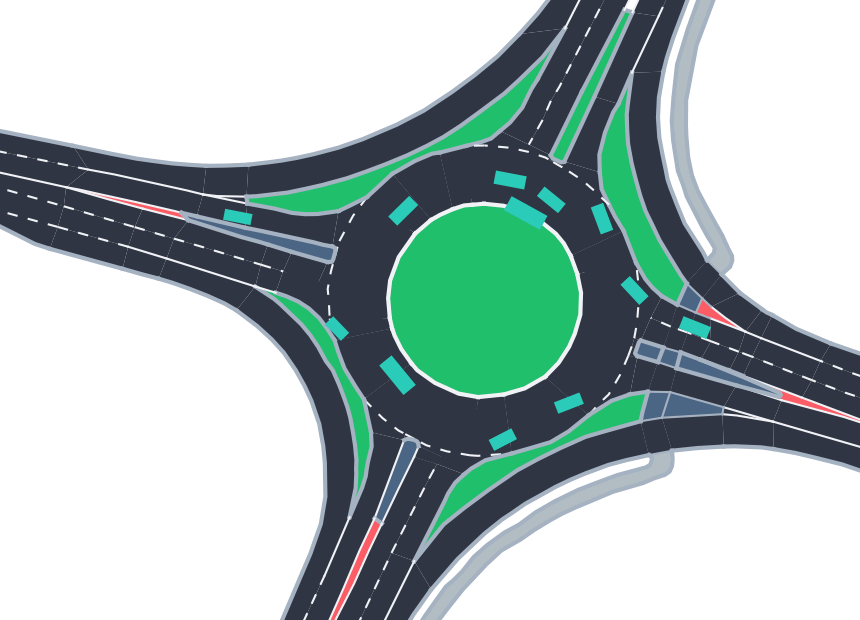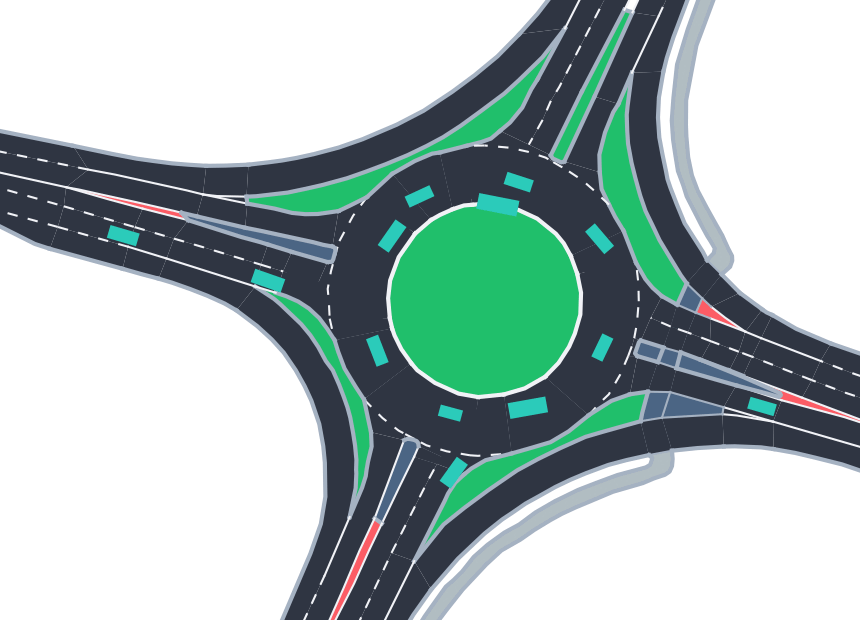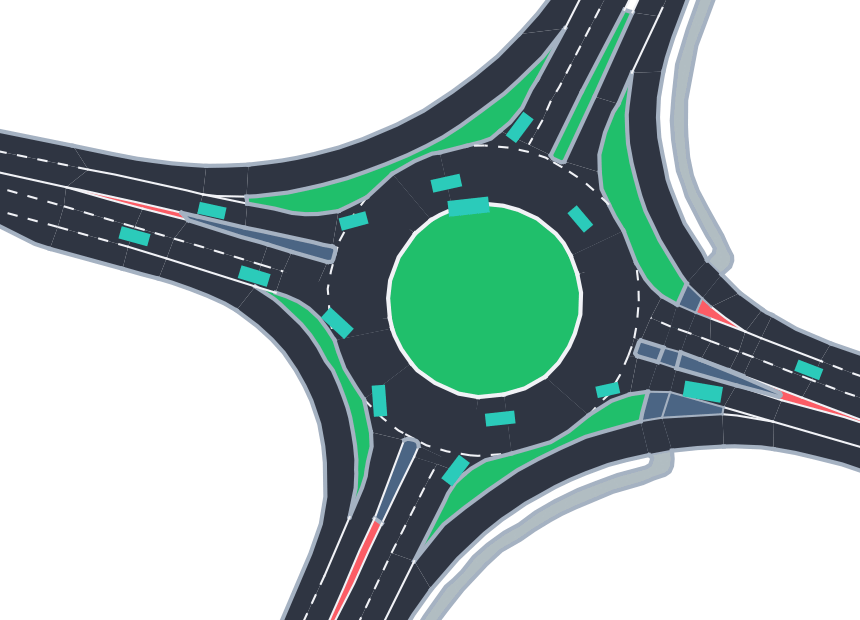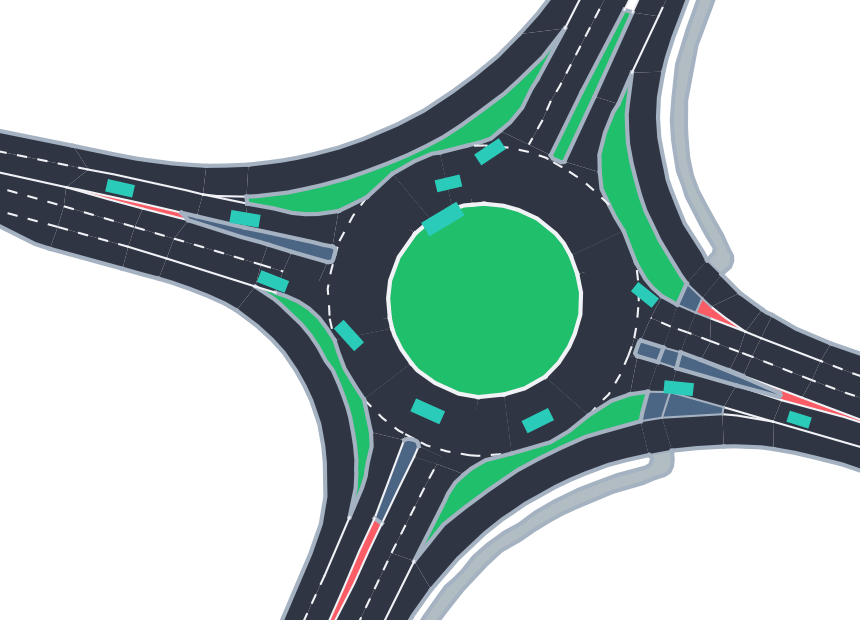
(Under Review) IEEE Transaction on Intelligent Transportation System(T-ITS), 2025
I am a second-year master's student in Control Science and Engineering at the University of Michigan–Shanghai Jiao Tong University Joint Institute, where I work under the supervision of Dr. Hanyang Zhuang at the CyberC3 Intelligent Vehicle Lab, led by Prof. Ming Yang. I received my bachelor’s degree in Artificial Intelligence from Shanghai Jiao Tong University.
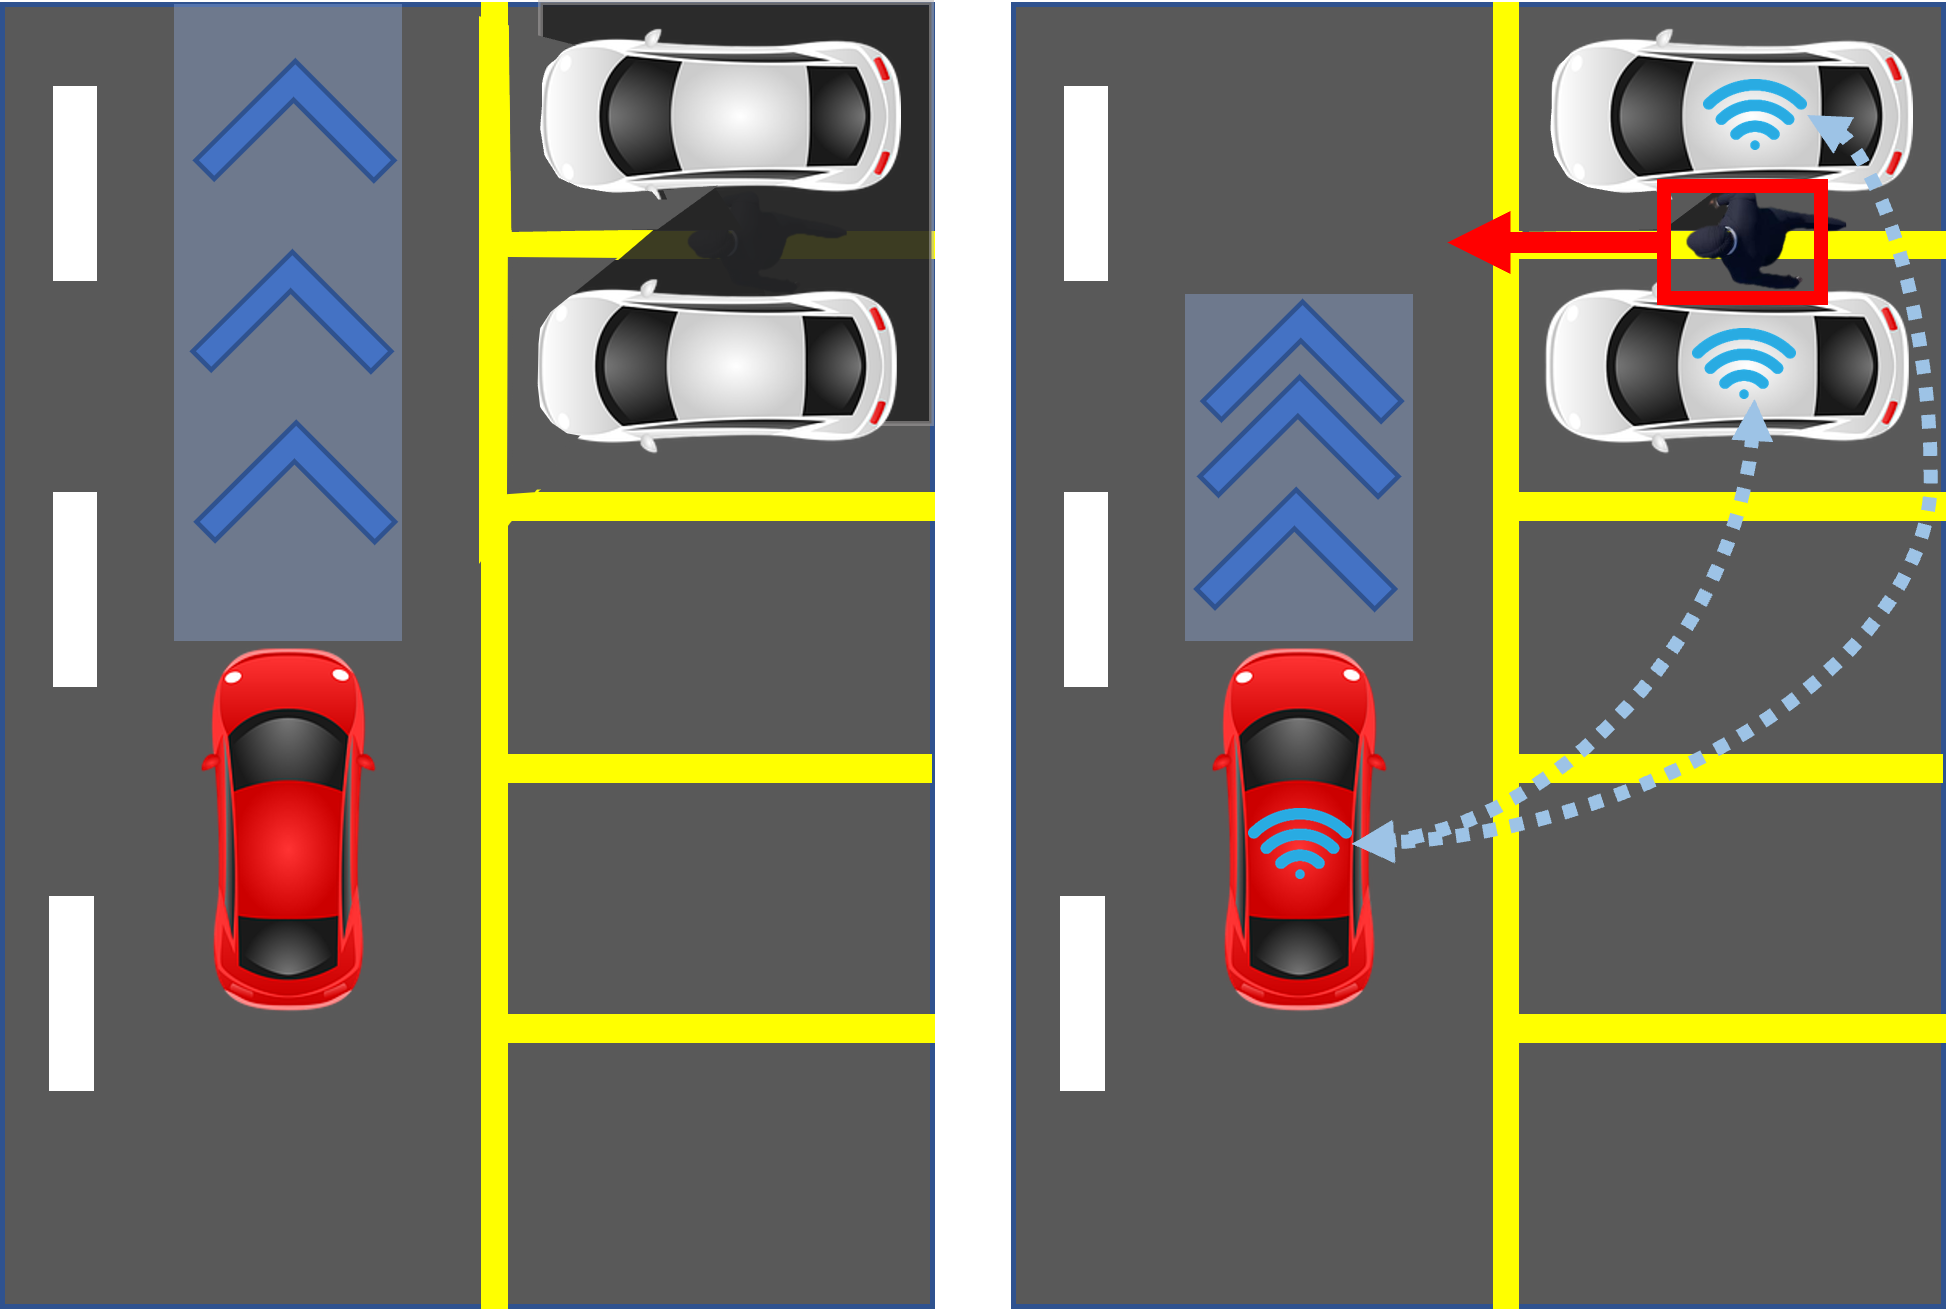
My research focuses on multi-vehicle cooperative perception , aiming to develop robust and efficient V2V (Vehicle-to-Vehicle) and V2X (Vehicle-to-Everything) technologies for real-world deployment. I am also deeply interested in control systems for autonomous vehicles and robotics , with a passion for building intelligent, safe, and scalable solutions for future transportation systems.
(Under Review) IEEE Transaction on Intelligent Transportation System(T-ITS), 2025
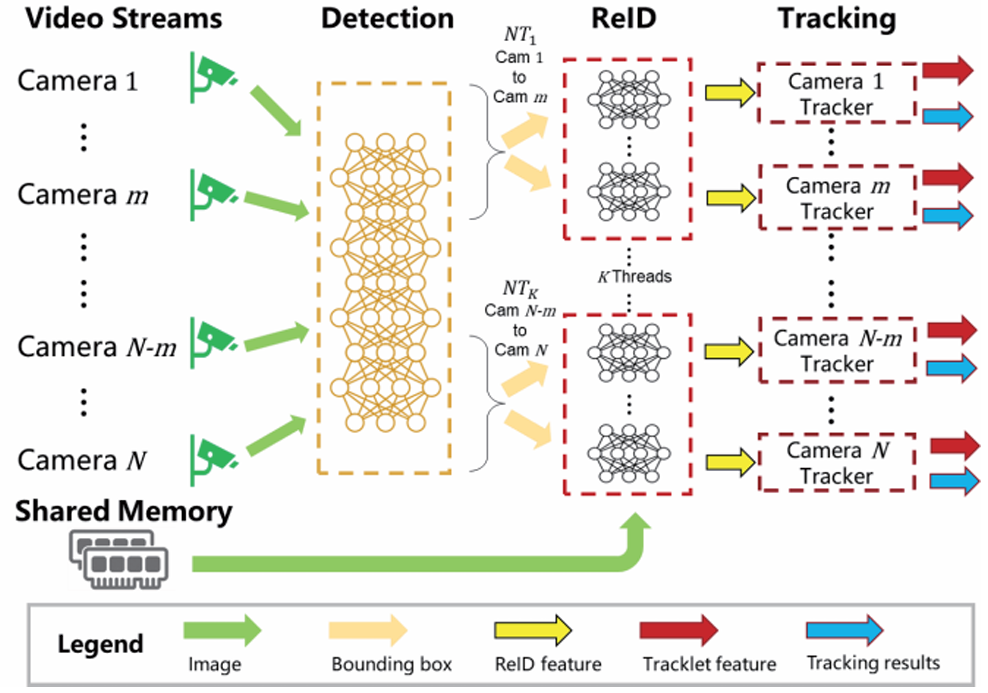
IEEE International Conference on Real-time Computing and Robotics (RCAR), 2024
I participated in a project focused on improving motion planning multi-modality for autonomous vehicles. My work involved researching trajectory prediction and applying perturbation-based data augmentation techniques using reinforcement learning methods within the CARLA simulation environment.
I contributed to the mining and preprocessing of lane change scenarios aimed at mitigating undesirable lane change behaviors in autonomous driving systems. Specifically, I developed a vision-language model (VLM)-based scenario checker to identify and filter invalid early and late lane change instances within urban intersection datasets.
Work for robotic dog navigation and we are still working on it